typed op• Data kinds: points → rgbimage
• Call: fullseye.apply(img, "tb_points_render", a=0.5, b=0.5) (the 2-D model is one image plus two scalar knobs a,b∈[0,1])
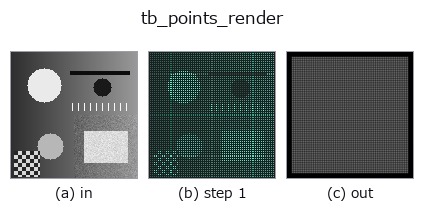
*The figure is the actual output on a synthetic 128×128 input. Left: input, right: output. Point clouds are drawn as a top-down scatter (brightness = z), 1-D series as a line plot, volumes as the maximum-intensity projection along z, videos as the middle frame, complex images as magnitude; return values that are not pictures are shown as the values themselves.*
Sweeping knob a (0.1 / 0.5 / 0.9, the other knob at its default):
▸ tb_points_render: knob a sweep (docs site)
Sweeping knob b (0.1 / 0.5 / 0.9, the other knob at its default):
▸ tb_points_render: knob b sweep (docs site)
Stages (the ops that come before → this op, left to right):
▸ tb_points_render: stages (docs site)
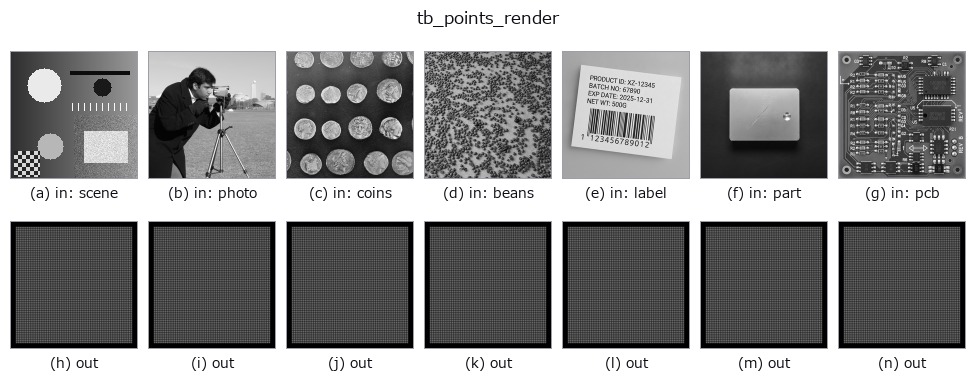
On other images (synthetic scene / photo / coins. Top row: inputs, bottom row: their outputs. Knobs at default):
▸ tb_points_render: other inputs (docs site)
Render an (N, 3) point cloud to an RGB image (H, W, 3): anti-aliased splats, depth-sorted, deterministic.
> The detailed description below is the original text — the summary and the headings are translated.
カメラは project_points / render_point_depth と同じ OpenCV の規約:
P_cam = R @ P + t(+Z が前、u が右、v が下)。画素 (row=r, col=c) の中心が連続座標 (u, v) = (c, r)(このモジュール冒頭の画素中心の規約。0.5 を足さない)。
• projection="orthographic": u = fx·X + s·Y + cx、v = fy·Y + cy(Z は順序だけに使う)。K が None なら自動で収める: R, t を当てた後の XY の箱が、縁 margin(画像の短辺に対する割合)を残して画像に入る最大の等方倍率で、箱の中心を画像の中心 ((W-1)/2, (H-1)/2) に置く。
• projection="perspective": u = fx·X/Z + s·Y/Z + cx、v = fy·Y/Z + cy。Z ≤ 0 の点(カメラの後ろ)は描かない。透視は距離が決まらないと収められないので K が要る(None は拒否)。
足跡(footprint、半径 radius_px 画素):
• "gaussian": 重み w = exp(-d²/(2σ²))、σ = radius_px / 2(半径 = 2σ)。|Δu| か |Δv| が 4σ を超える画素は 0(円でなく軸ごとに切るので足跡は x と y の積に分かれ、加算の像の列の和は点の行の位置に依らない)。像の重心は射影位置に 1e-3 画素以内で乗る(3σ で切ると切り口の非対称で 0.017 画素ずれた。実測)。
• "disc": 半径 radius_px の円の画素被覆を 1 画素幅の線形ランプで近似 w = clip(radius_px + 0.5 - d, 0, 1)(縁が階段にならない)。小さな円は画素に量子化されるので、像の重心のずれは半径 1〜1.5 画素で最大 0.05 画素(小数画素の位置を測るなら gaussian)。
• "point": 最寄りの 1 画素だけ(round、render_point_depth と同じ画素)。
d は点の射影位置(小数画素のまま)から画素中心までの距離 —— 点を画素に丸めてから円を置くのではないので、0.3 画素ずれた点の像は 0.3 画素ずれる。
重ね方(composite):
• "over"(既定): 画素ごとに手前からアルファ合成 C = Σ c_i α_i T_i、T_i = Π_{j が手前}(1 - α_j)、α_i = opacity · w_i(足跡の重みは最大 1)、最後に (1 - Σ α_i T_i) · background。順序は深さ Zで決め、入力の並びには依らない(Z が等しい点どうしだけ入力の番号順。丸めの屑で入れ替わらないよう Z の同点は番号で決める)。opacity = 1 で足跡の中心(w = 1)に来た点は、その画素で後ろを完全に隠す(z-buffer と同じ勝ち方)。積は log を取らずに層ごとに掛けるので、不透明な点の後ろの透過率は厳密に 0。
• "add": 足跡を和が 1 に正規化して足す C = background + Σ opacity · c_i · ŵ_i。画像に収まった点については光の総量が厳密に保存される(Σ (C - background) = Σ opacity · c_i)。密度の絵で、値は 1 を超えうる(切らない。トーンは呼び手が決める)。
colors: None なら一様な明るい灰 (0.9, 0.9, 0.9)。(3,) なら全点に 1 色、(N, 3) なら点ごと。値は 0〜1。depth_cue(0〜1): 描かれる点の Z を手前 0・奥 1 に正規化した zn で、色に 1 - depth_cue · zn を掛ける(奥ほど暗い。0 で無効)。background: 背景の RGB(0〜1)。size: (H, W) か整数(正方)。
返り値: float64 の (H, W, 3)。"over" なら 0〜1 に収まる。
fail-closed(ValueError): 点が (N, 3) でない・有限でない、空の入力(points が 0 要素)、色の形か値域が違う、未知の projection / footprint / composite、radius_px ≤ 0、opacity が (0, 1] の外、depth_cue が [0, 1] の外、margin が [0, 0.5) の外、画素数が MAX_PIXELS 超、透視で K が無い、K が 3×3 でない・fx か fy が 0、点 × 足跡の組が POINTS_RENDER_MAX_PAIRS を超える。画像に 1 点も入らないのは拒否しない(背景だけの画像が正しい答え)。
後段: tonemap_reinhard / antialias、図は imgio で保存。深度だけなら render_point_depth。
2-D 進化レジストリへ橋渡しした 3d の op points_render。実装は同じで、呼び出し規約だけ op(v, a, b) に合わせてある。a が radius_px(既定 1.5)、b が opacity(既定 1)を振る。
• Sample-data catalog (download URLs / licences) — 2-D uses skimage.data (BSD/public domain) plus synthetic images; 3-D lists download URLs for real data sources (Stanford, PDS, …).
• Operator provenance and references — the sources of the research/methods this op family came from.
The program below has been verified to run (same input as the figure). In Studio's help this block becomes buttons that load and run it on the spot.
img_to_points 0.50 0.50
tb_points_render 0.50 0.50
▸ Load this pipeline · Load & run
The examples below call the underlying ledger op points_render. This bridge op is the same implementation adapted to the fn(v, a, b) convention, so the behaviour carries over unchanged (only the call form differs).
• points_render_basics — py -3.11 examples_3d/points_render_basics.py
rgbimage as input)identity · tb_wetness · tb_sensor_capture · tb_specular_diffuse_split · tb_specular_coefficient_map · tb_specular_free_transform · tb_rgb_to_quaternion
typed)tb_points_to_voxel · tb_estimate_point_normals · tb_iss_keypoints · tb_project_points · tb_render_point_depth · tb_statistical_outlier_removal · tb_radius_outlier_removal · tb_voxel_grid_downsample
*Provenance: ops.py — 2D operator registry. This per-op note is generated by tools/opdocs.py md (do not hand-edit).*
© 2026 Kazufumi Furuse — Fullseye operator documentation. Licensed under Apache-2.0.