typed op• Data kinds: signal → signal
• Call: fullseye.apply(img, "tb_magnus_lift_coefficient", a=0.5, b=0.5) (the 2-D model is one image plus two scalar knobs a,b∈[0,1])
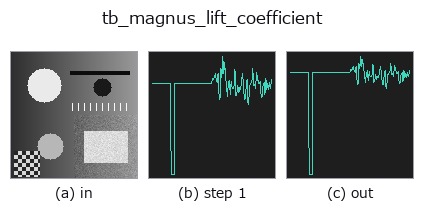
*The figure is the actual output on a synthetic 128×128 input. Left: input, right: output. Point clouds are drawn as a top-down scatter (brightness = z), 1-D series as a line plot, volumes as the maximum-intensity projection along z, videos as the middle frame, complex images as magnitude; return values that are not pictures are shown as the values themselves.*
*Knob a does not change the output (measured: identical at 0.1 / 0.5 / 0.9).*
*Knob b does not change the output (measured: identical at 0.1 / 0.5 / 0.9).*
Stages (the ops that come before → this op, left to right):
▸ tb_magnus_lift_coefficient: stages (docs site)
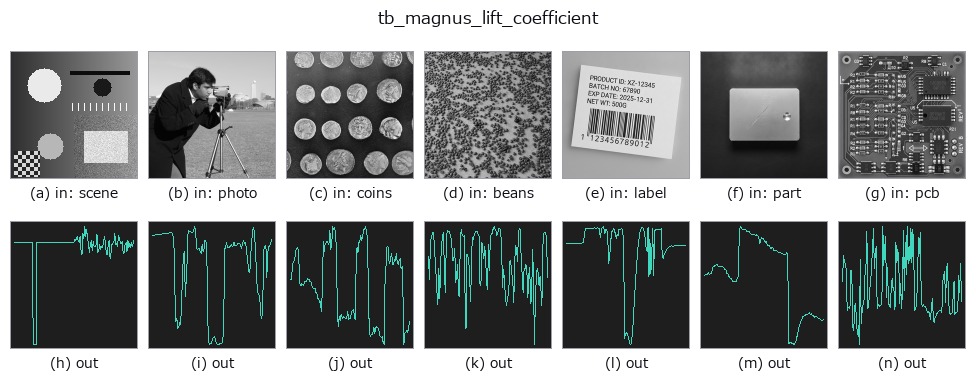
On other images (synthetic scene / photo / coins. Top row: inputs, bottom row: their outputs. Knobs at default):
▸ tb_magnus_lift_coefficient: other inputs (docs site)
> This operator's description has not been translated yet. The original text follows as it is.
スピン比 S = rω/|v| から揚力係数 C_L = 1 / (2 + 1/S)(S → 0 で 0、S → ∞ で 0.5。球の文献で広く使われる経験式)。
2-D 進化レジストリへ橋渡しした drive の op `magnus_lift_coefficient。実装は同じで、呼び出し規約だけ op(v, a, b) に合わせてある。この op に調整点は無く、a も b` も使われない。
• Sample-data catalog (download URLs / licences) — 2-D uses skimage.data (BSD/public domain) plus synthetic images; 3-D lists download URLs for real data sources (Stanford, PDS, …).
• Operator provenance and references — the sources of the research/methods this op family came from.
The program below has been verified to run (same input as the figure). In Studio's help this block becomes buttons that load and run it on the spot.
img_to_signal 0.50 0.50
tb_magnus_lift_coefficient 0.50 0.50
▸ Load this pipeline · Load & run
• (none yet)
signal as input)identity · tb_create_funct_1d_array · tb_smooth_funct_1d_gauss · tb_smooth_funct_1d_mean · tb_derivate_funct_1d · tb_integrate_funct_1d · tb_zero_crossings_funct_1d · tb_abs_funct_1d
typed)tb_points_to_voxel · tb_estimate_point_normals · tb_iss_keypoints · tb_project_points · tb_render_point_depth · tb_statistical_outlier_removal · tb_radius_outlier_removal · tb_voxel_grid_downsample
*Provenance: ops.py — 2D operator registry. This per-op note is generated by tools/opdocs.py md (do not hand-edit).*
© 2026 Kazufumi Furuse — Fullseye operator documentation. Licensed under Apache-2.0.